Overview
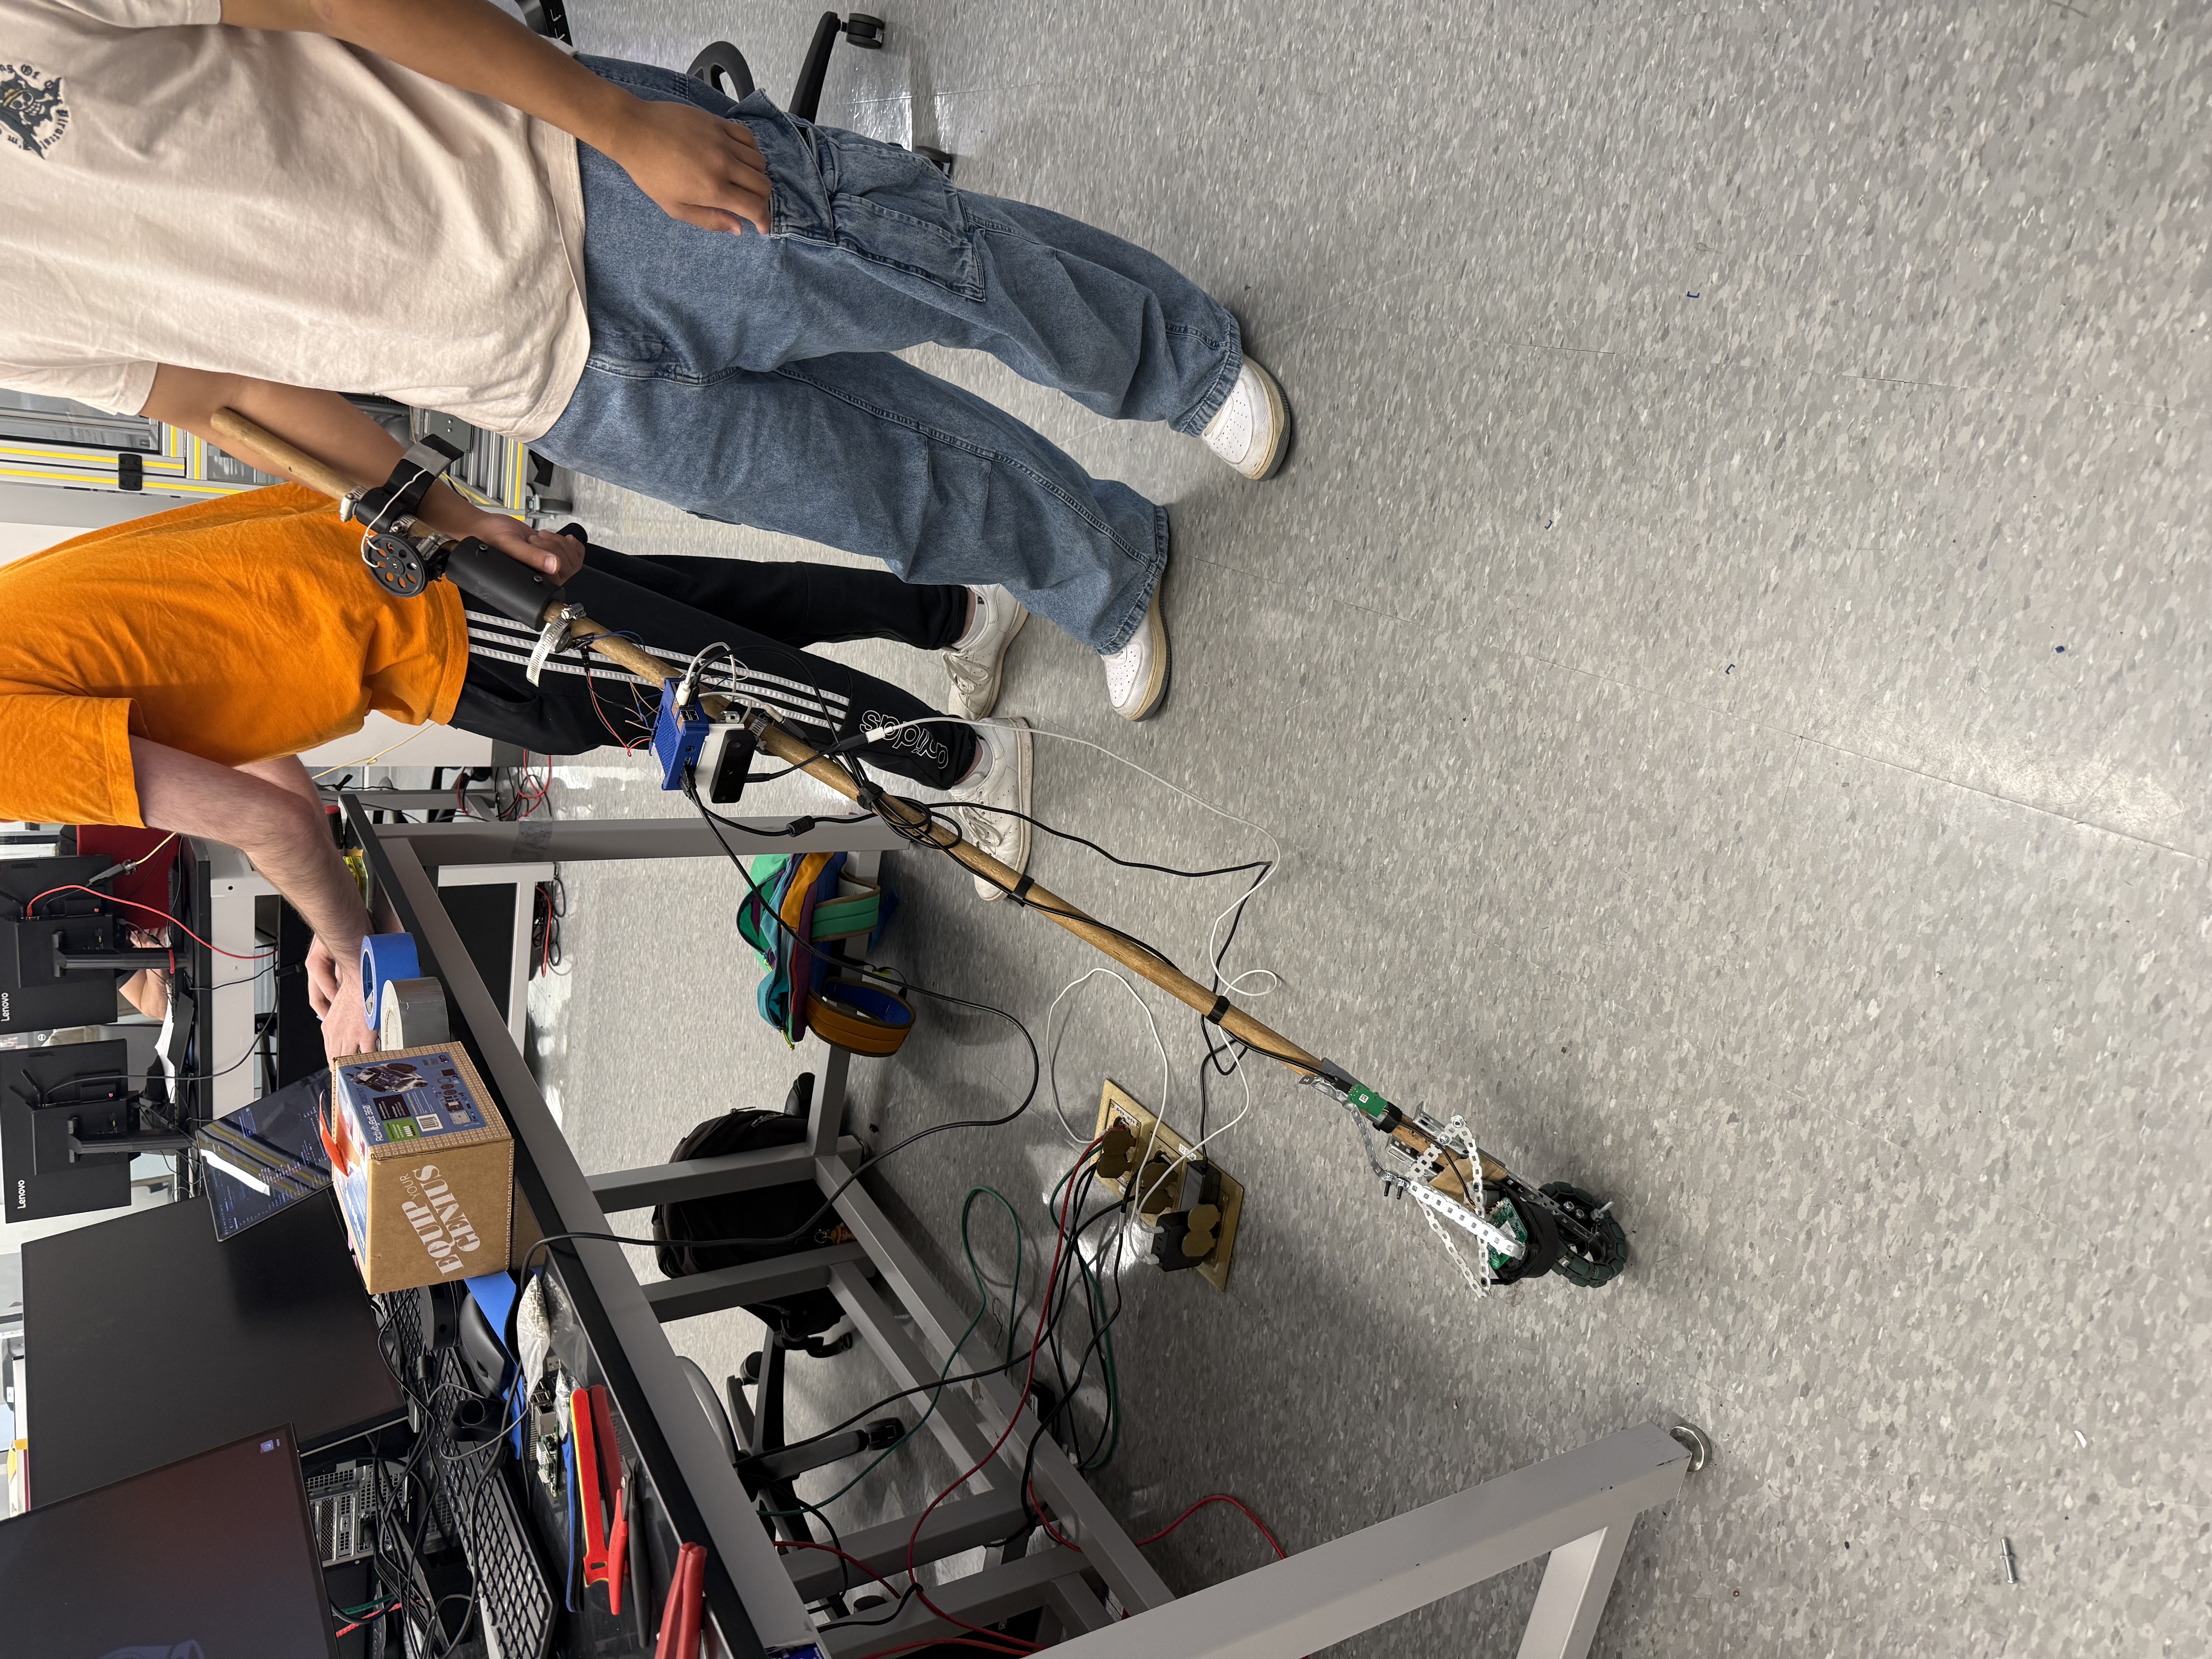
This team project augments a traditional cane with onboard sensing and feedback so users keep familiar tactile sweeping while gaining earlier awareness of obstacles beyond the cane tip. A Raspberry Pi 4 manages sensor input and triggers haptic cues when objects enter critical ranges.
Sensing is split between an Oak-D Lite depth camera for computer-vision object detection and an RP Lidar unit for planar ranging. Feedback is delivered through rumble motors and a servo-powered directional tap that indicates which side a detected threat is approaching from.
Object Detection
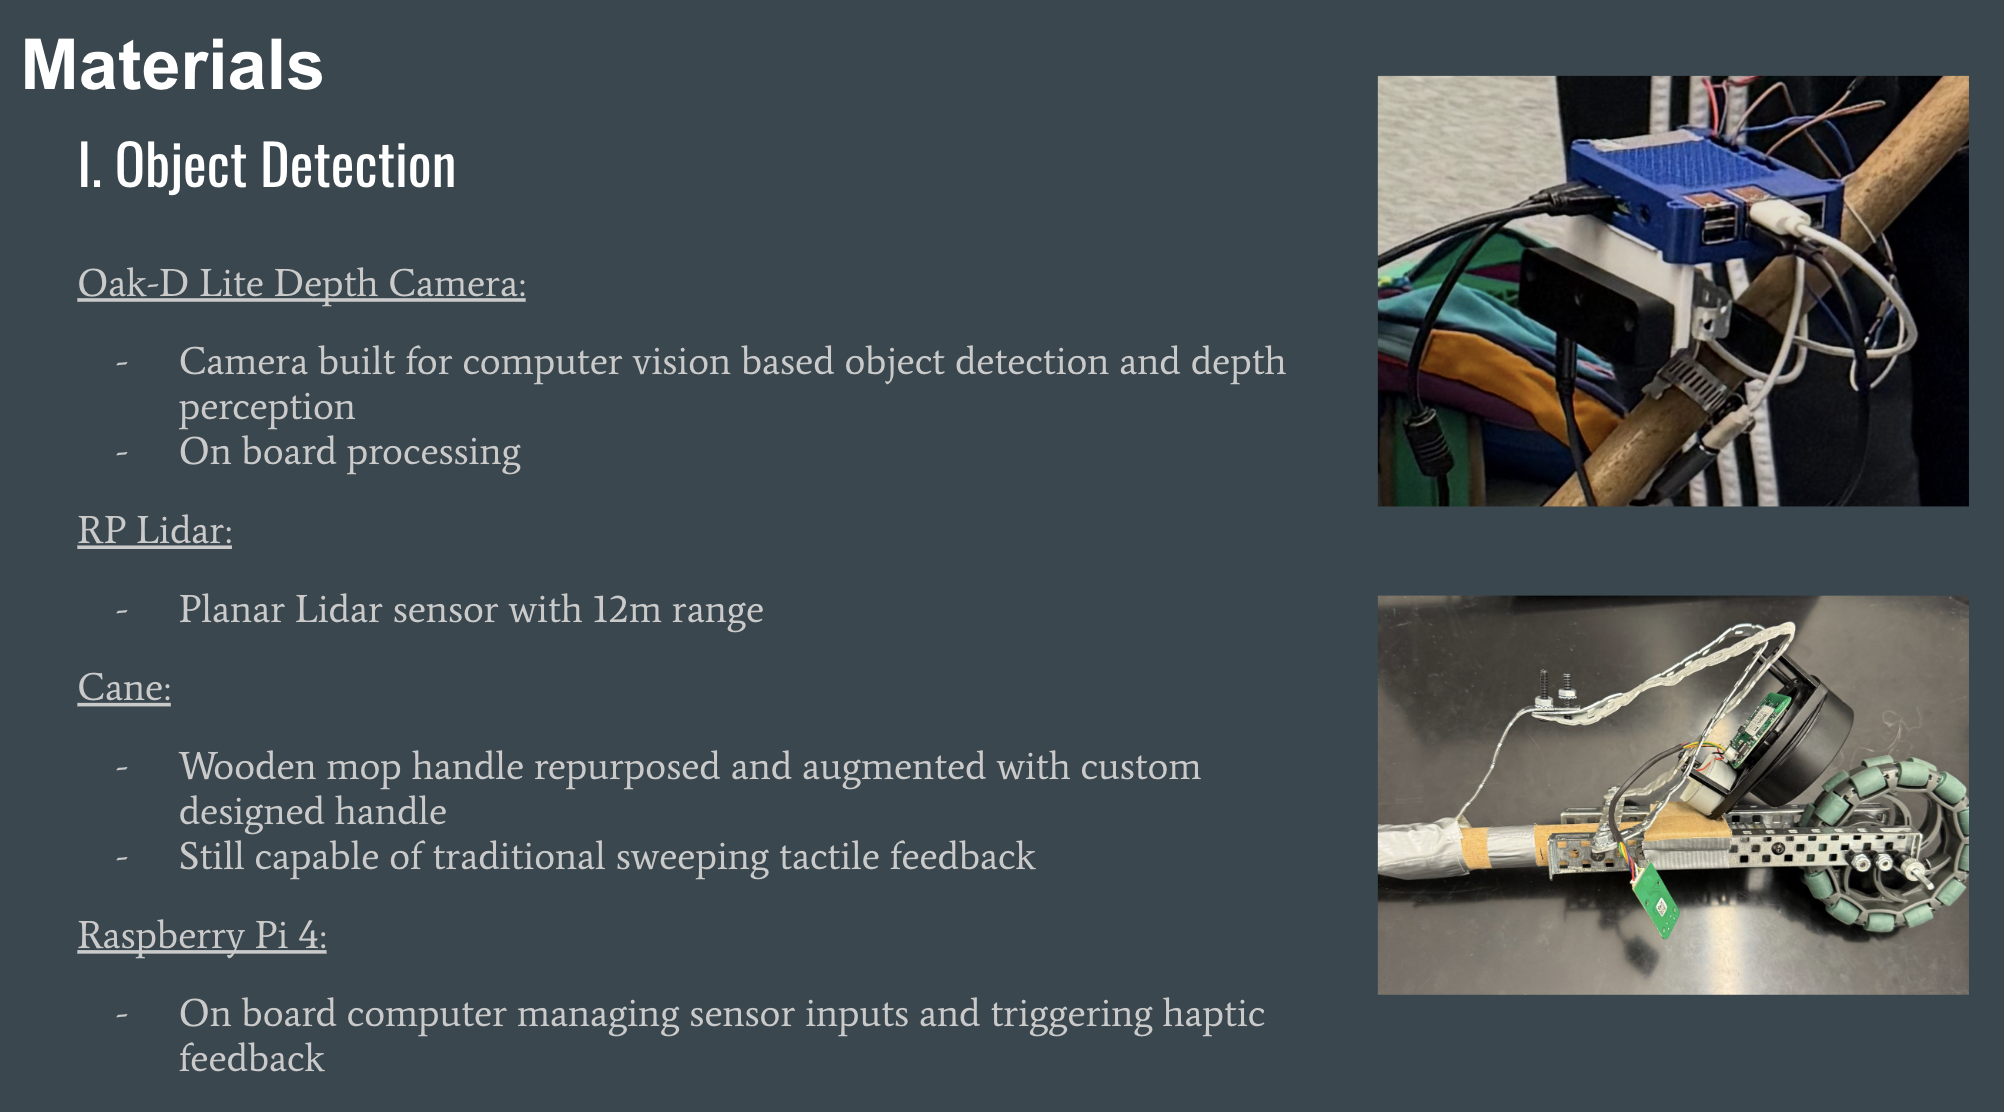
- Oak-D Lite depth camera with onboard processing
- RP Lidar with ~12 m planar range
- Wooden cane still usable for traditional tactile feedback
Haptic Feedback
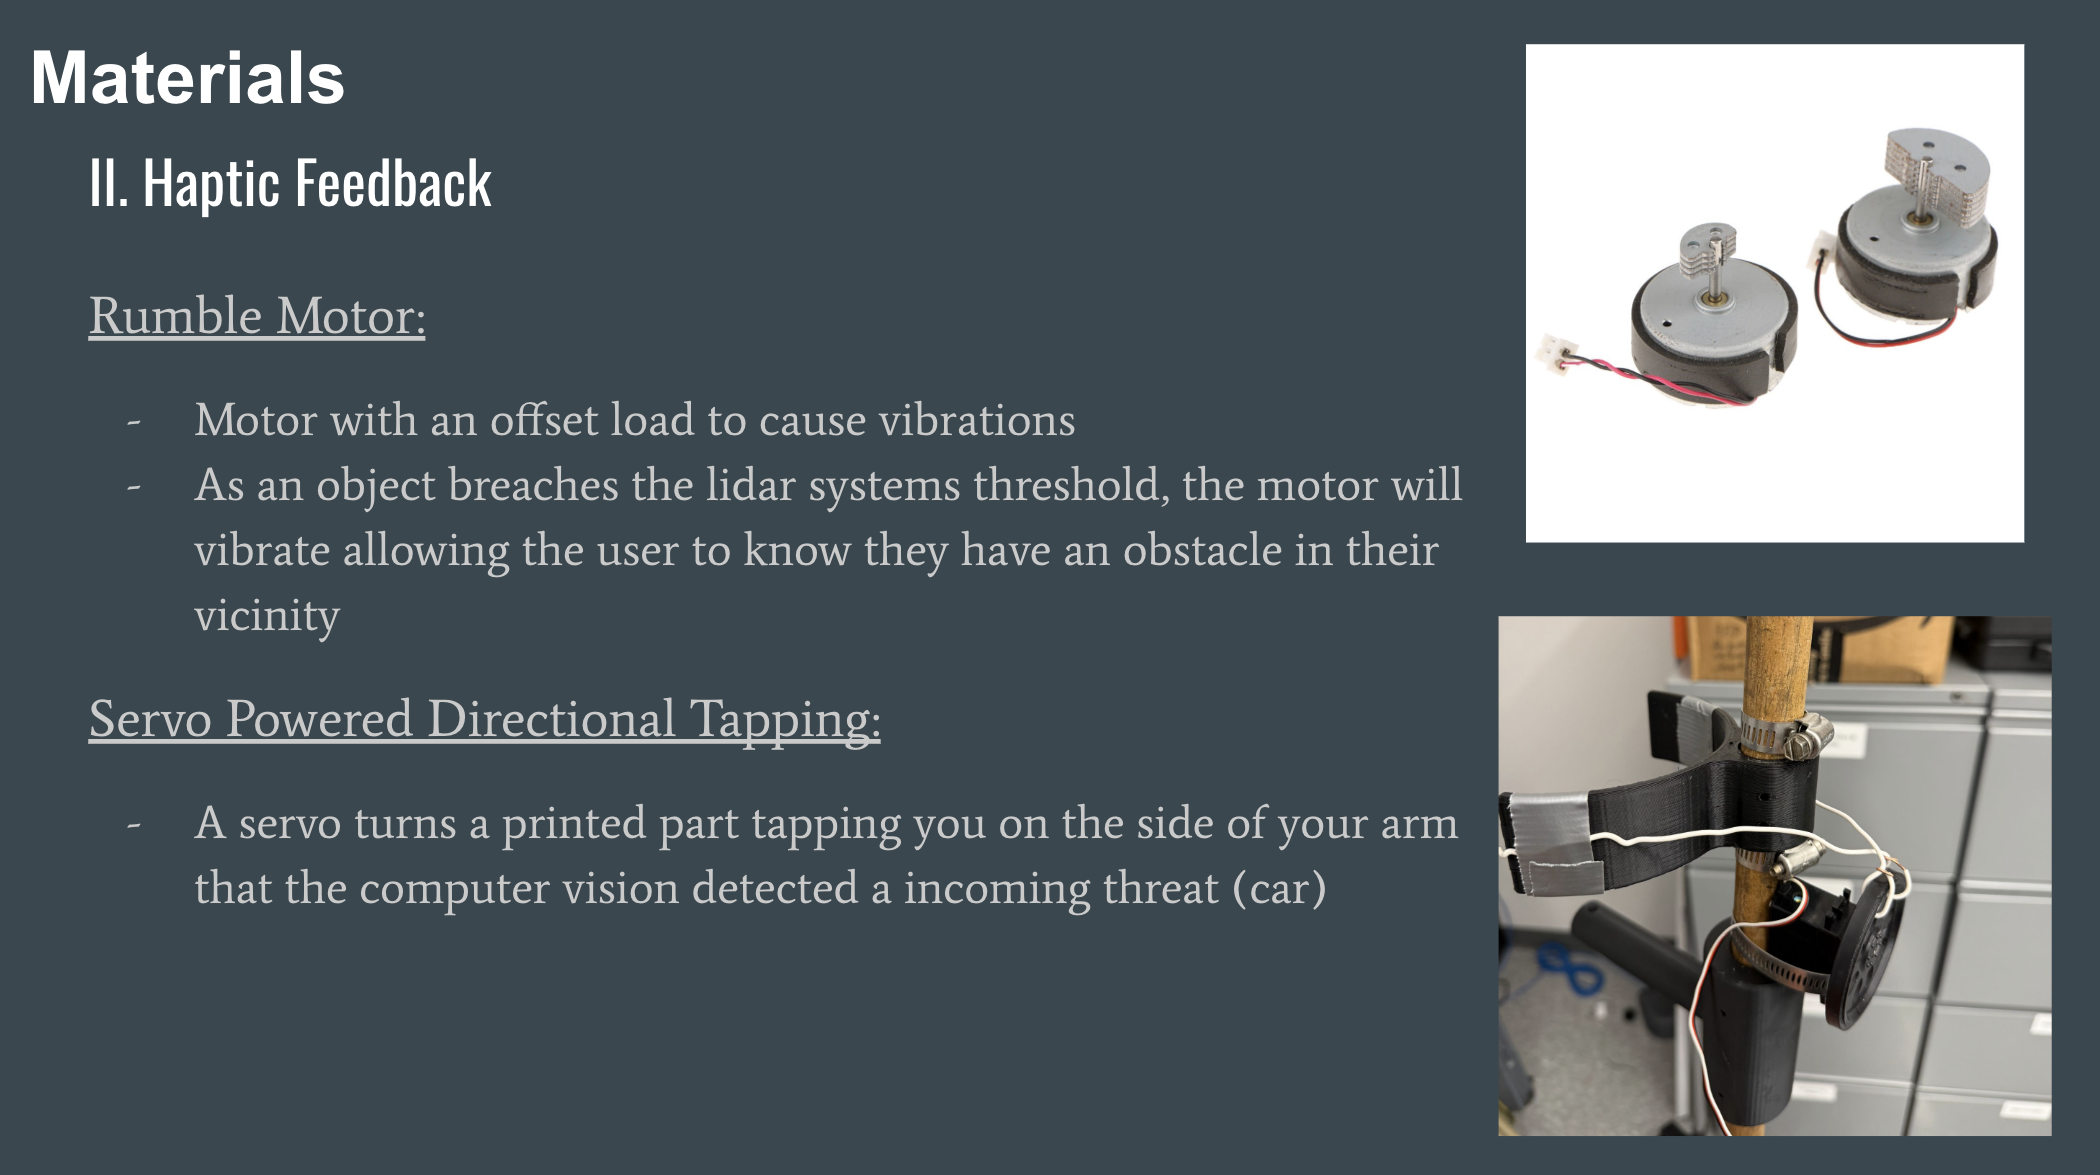
- Rumble motor vibrates when lidar threshold is breached
- Servo taps the arm on the side of a CV-detected threat
- Pi coordinates sensor fusion and feedback timing using ROS2
Prototype Build
- Repurposed mop-handle shaft with custom handle
- 3D-printed mounts and hose-clamp fixtures
Media