Overview
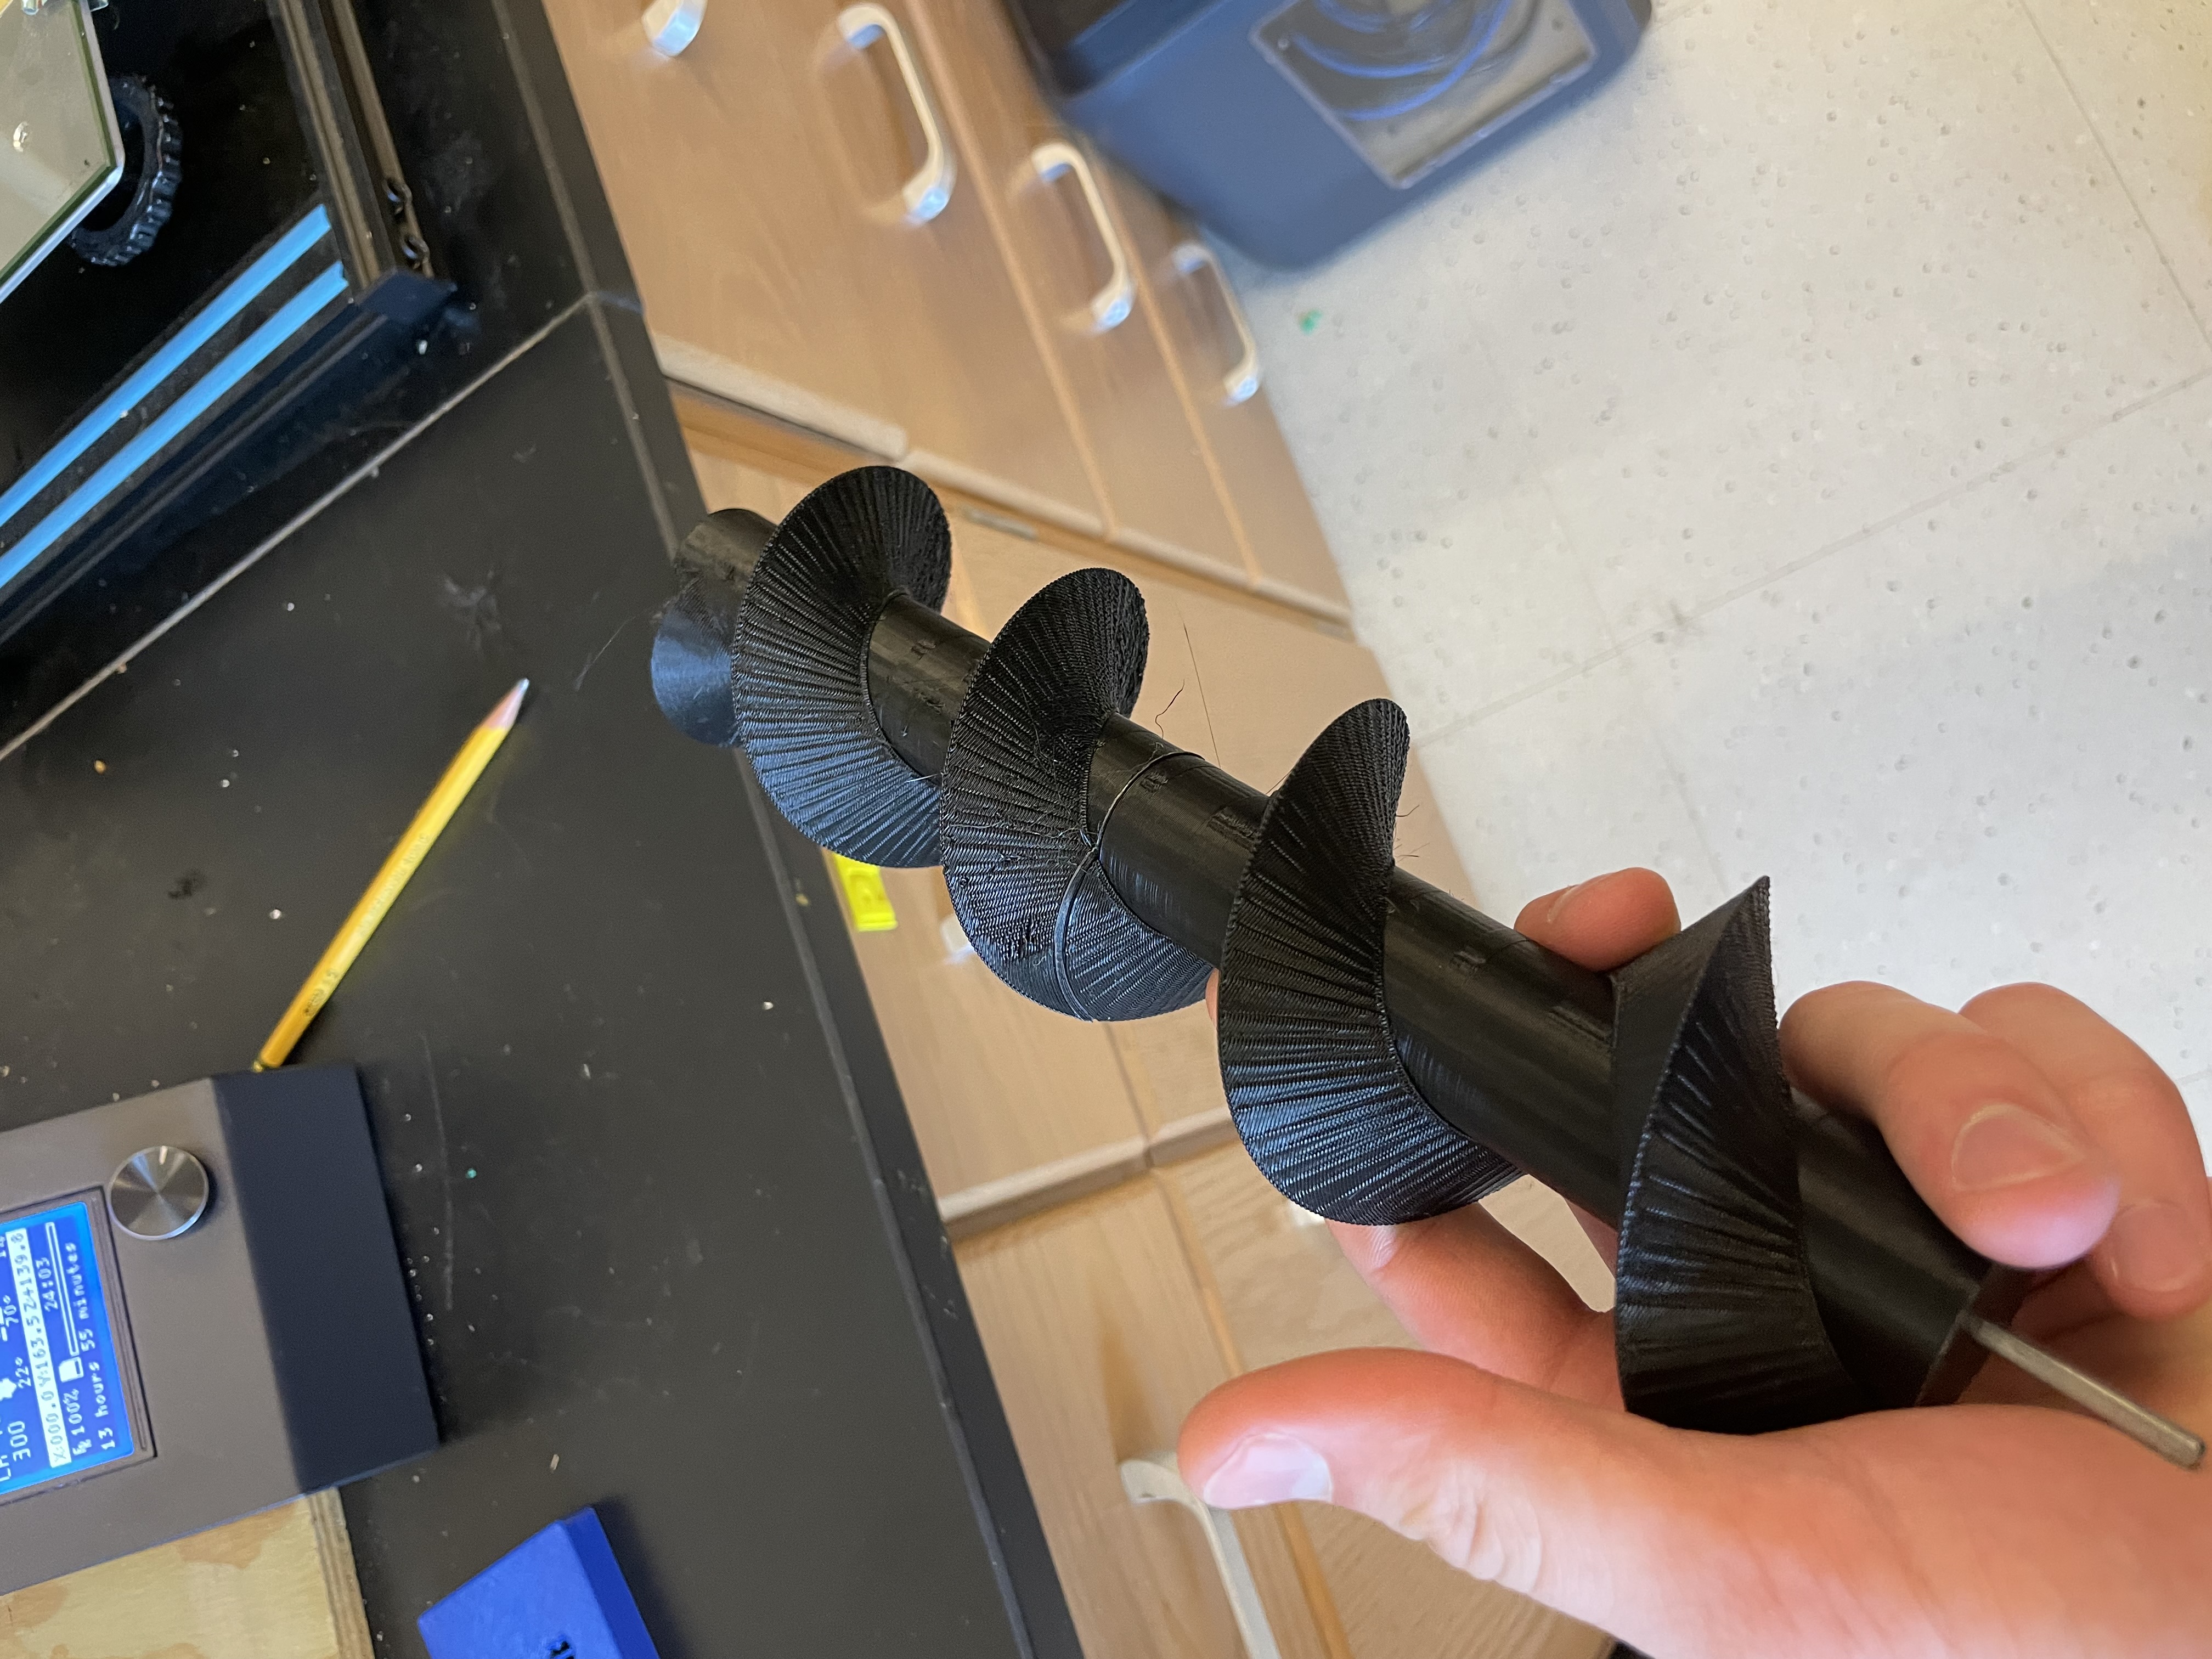
This team project was a robotic submersible concept aimed at moving through swamp and marshland for sample collection. The propulsion approach centers on Archimedes-screw (auger) drives that can push through water and soft terrain more gracefully than open blades.
This was my high school engineering capstone project. It was based around one of our teammates’ jobs that required traveling all day through difficult terrain to collect samples. Unfortunately, our senior year had several disruptions leaving the project unfinished. This was a team project, but most of the work on this page is my own because it is all I have photos of.
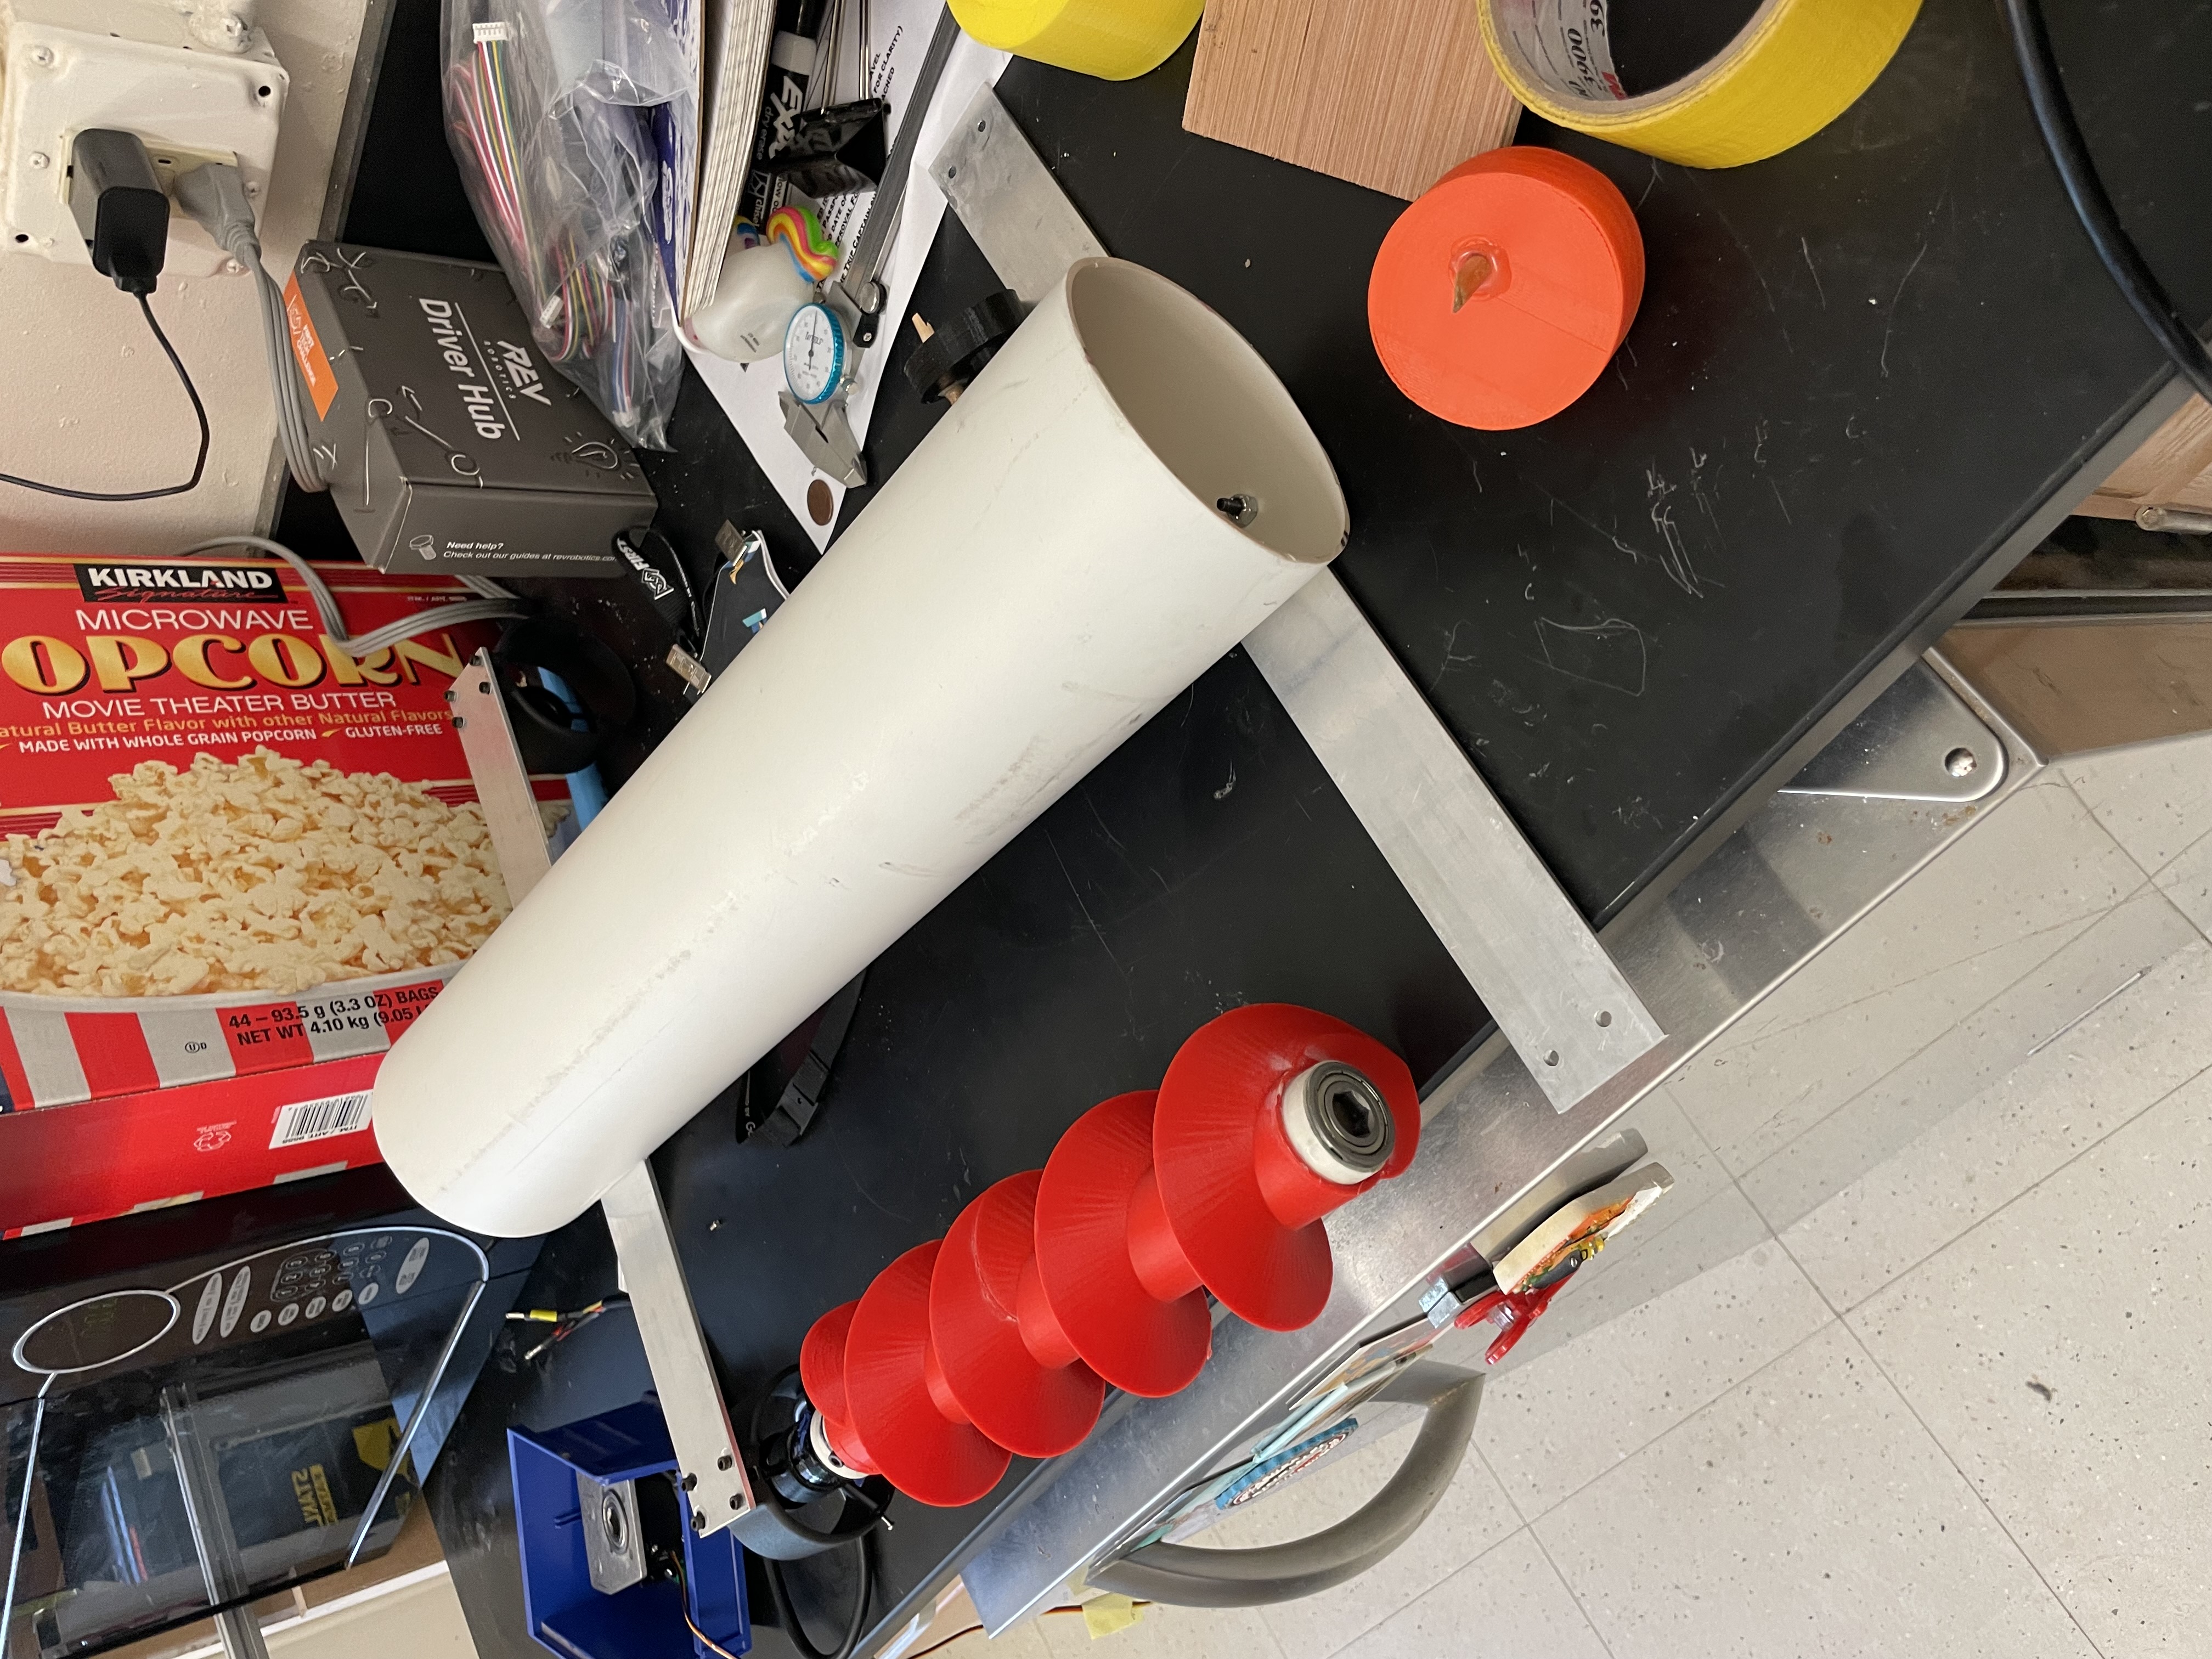
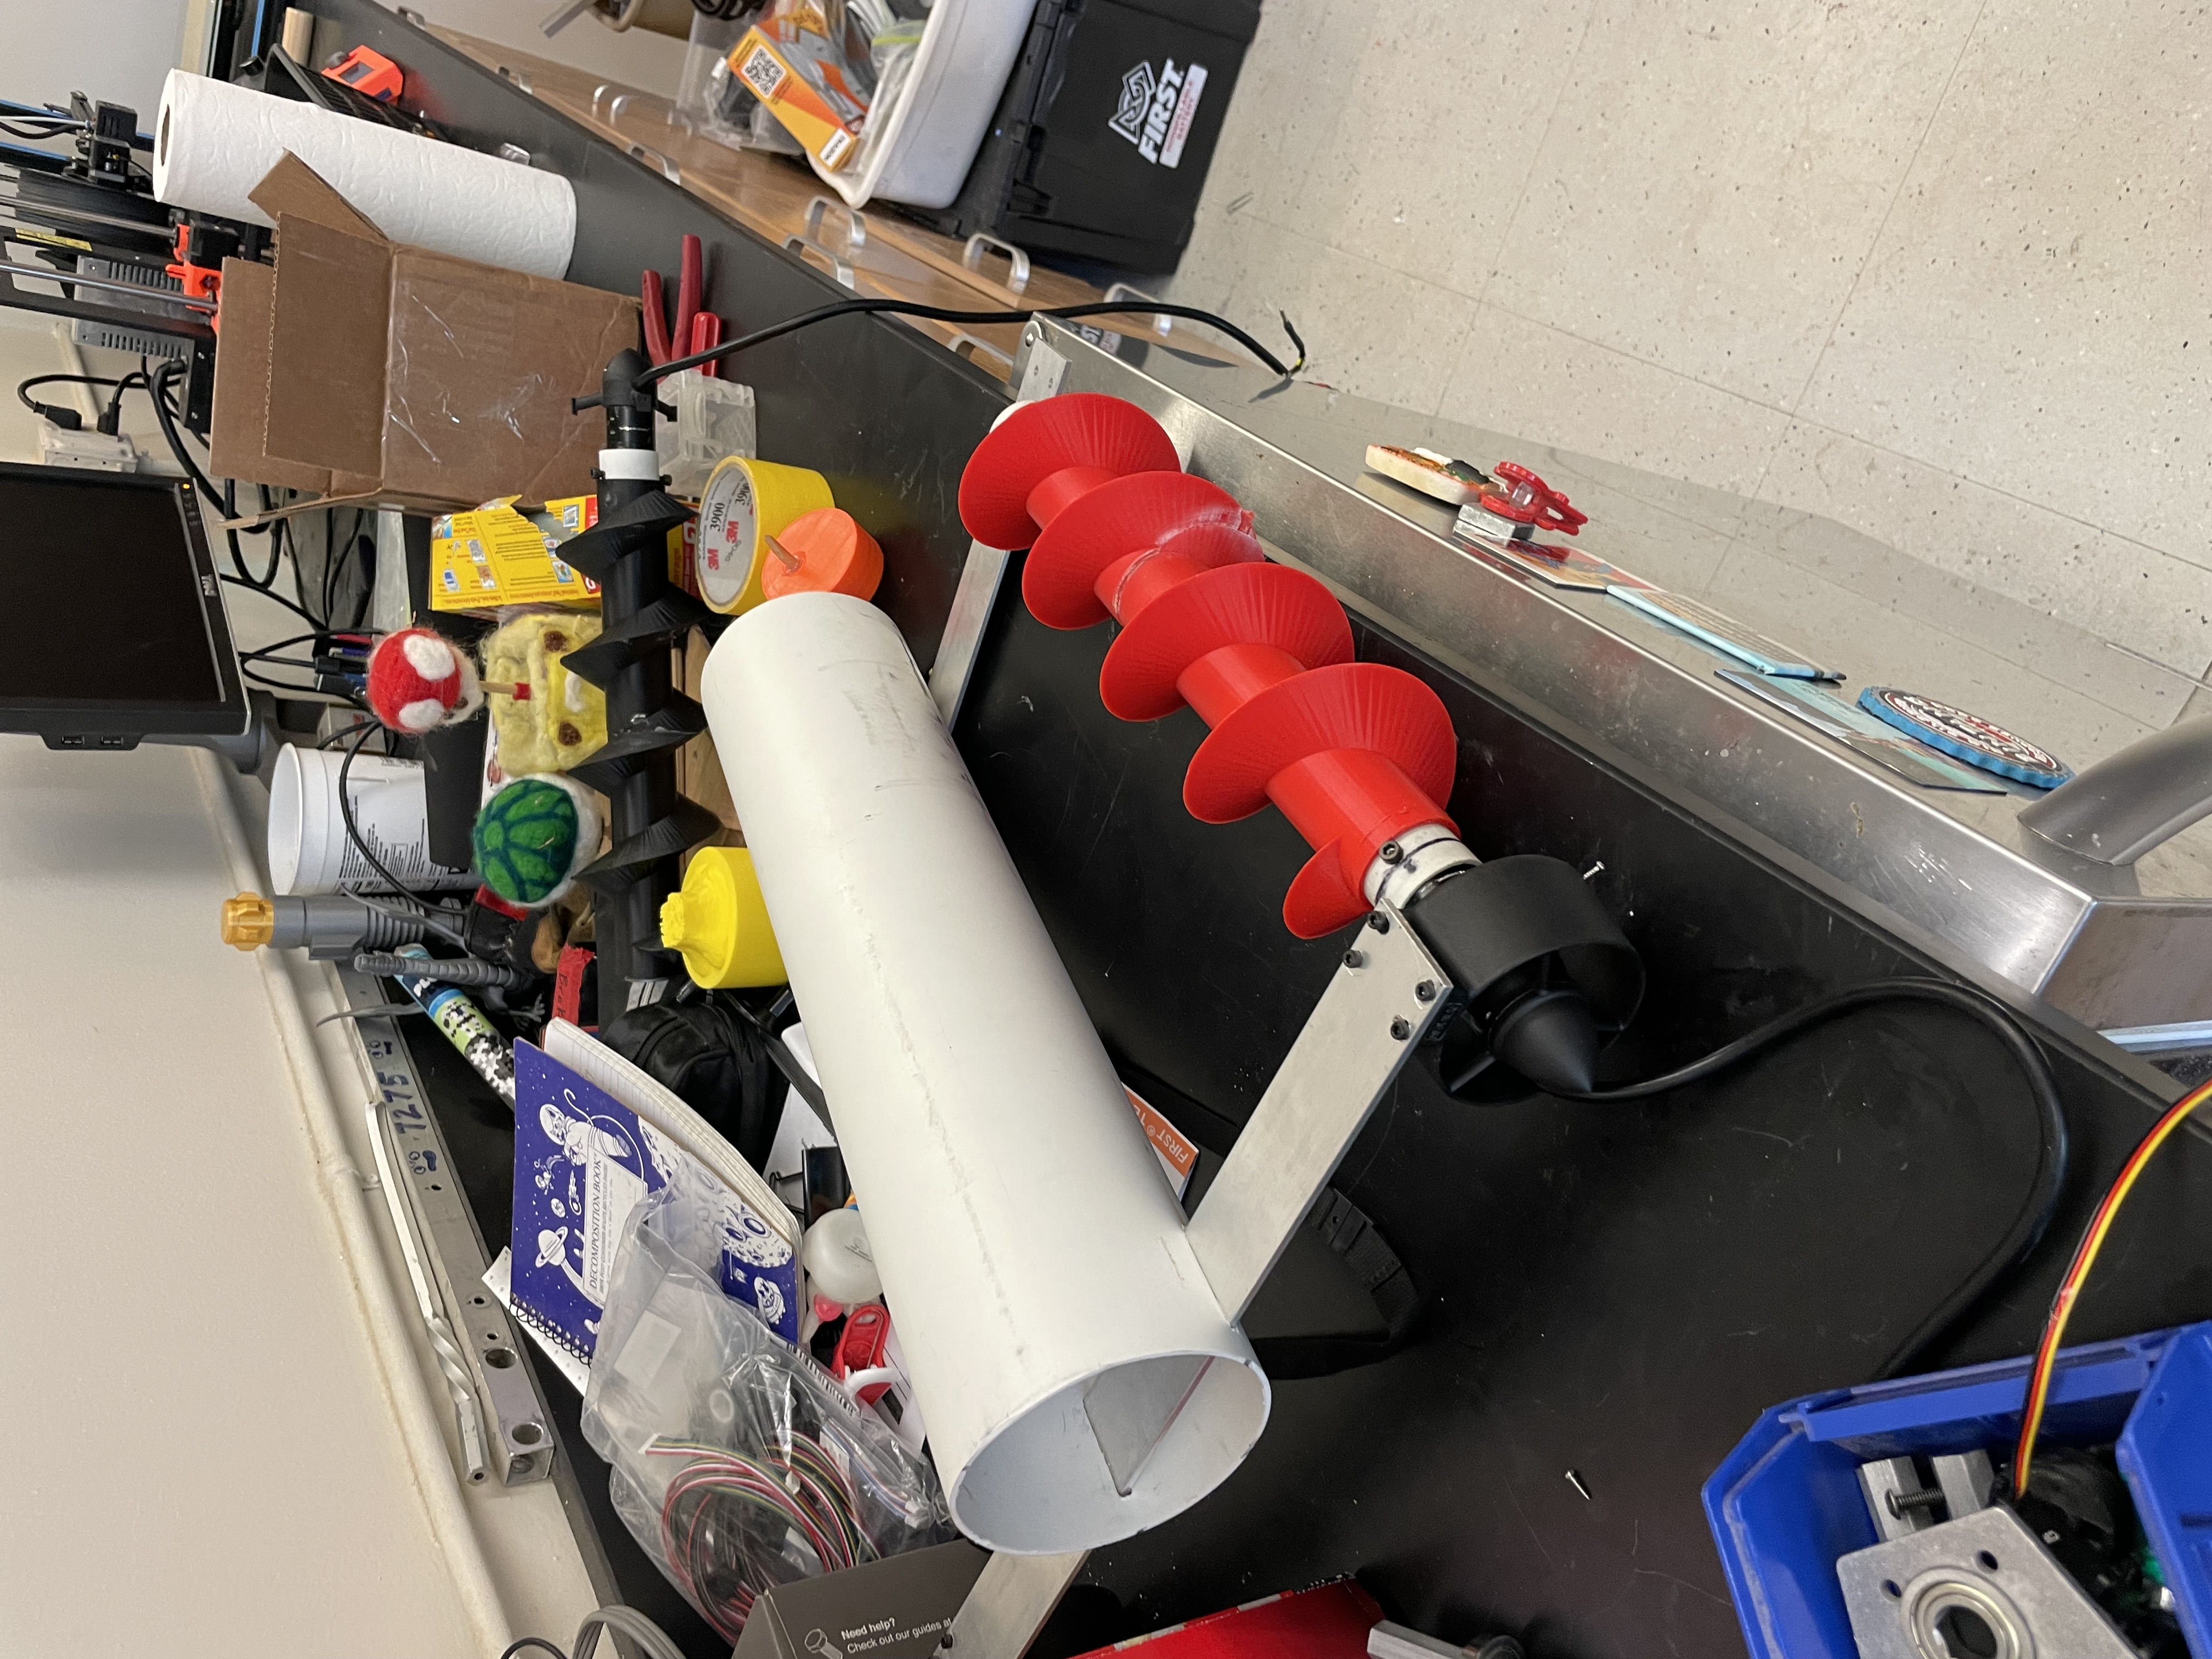
The build progressed from early screw prototypes and pool-frame tests to a more integrated hull package: a PVC body, aluminum structural rails, custom 3D-printed screws, and an underwater motor/thruster mounting for twin-screw propulsion.
Propulsion
- Custom 3D-printed Archimedes screws
- Twin-screw layout for balanced thrust
- Underwater motor / thruster mounting
Structure
- PVC pipe hull / buoyancy chamber
- Aluminum rail chassis and mounts
- Electronics kept elevated during early pool tests
Prototype Build
- Iterative screw geometry and materials
- Bench assembly before water trials
- Pool testing of drive and flotation behavior
Media